 Defining E-Mobility
Menu
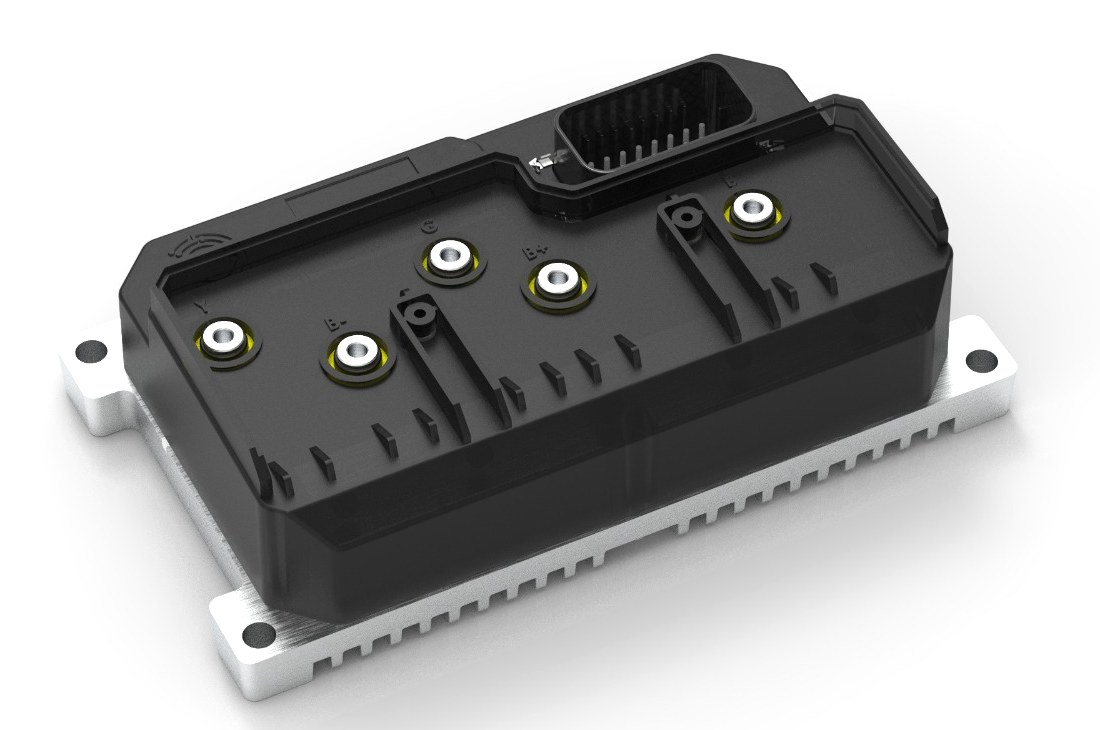
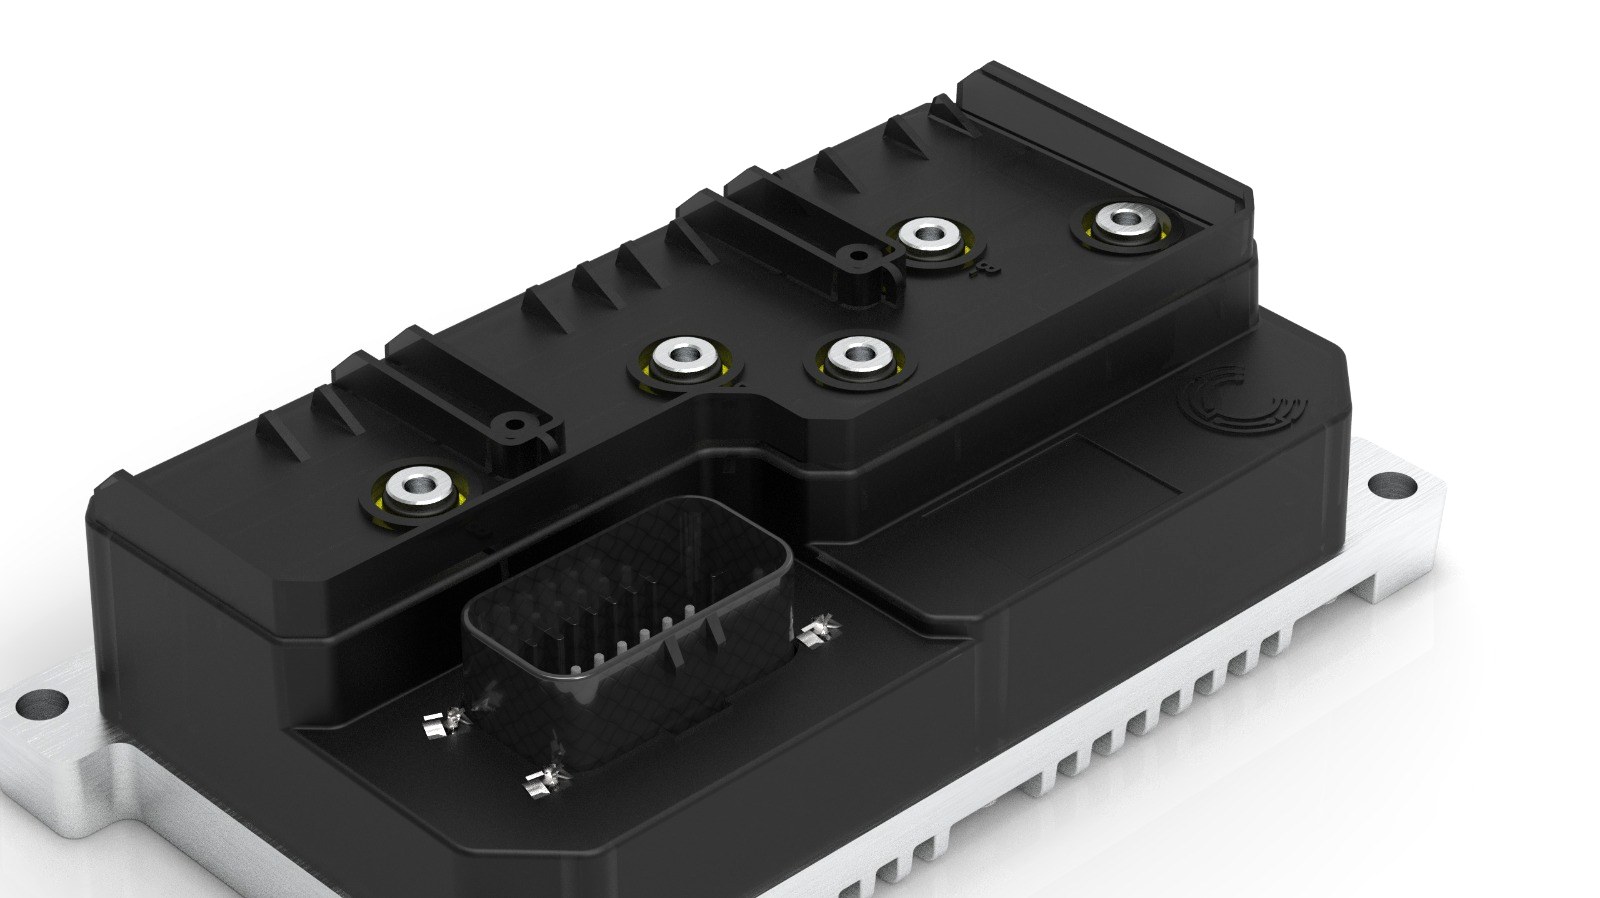
AMP600 series motor controllers
Our core controller family for e-scooters: up to 3.6 kW peak across 48 to 72 V. Designed and built in India.
Part numbers
| Part number | System voltage (V DC) | Phase current (Arms) | Power rating (kW) |
|---|---|---|---|
| AMP6605 | 48 / 60 | 50 | 1.5 |
| AMP6607 | 48 / 60 | 70 | 1.7 |
| AMP6609 | 48 / 60 | 90 | 2.1 |
| AMP6612 | 48 / 60 | 120 | 2.7 |
| AMP6614 | 48 / 60 | 140 | 3.6 |
| AMP6712 | 60 / 72 | 120 | 3.6 |
Specifications
- Applications
- E-scooters
- Motor mounting
- Mid-mount or hub-mount motors
- System voltage
- 48 V, 60 V, 72 V
- Peak power
- up to 3.6 kW
- Phase current
- up to 140 Arms
- Peak DC current
- up to 60 A for 30 s
- Controller hardware efficiency
- ~97%
- Motor types
- PMSM, BLDC
- Control
- FOC / vector control, torque control
- Position sensor
- Hall sensors, incremental encoder (A, B, I, Z), sin-cos encoder or resolver
- Motor temperature sensor
- NTC or PTC
- Ride modes
- 4, including reverse
- Regenerative braking
- Programmable regen current
- Communication
- CAN 2.0B, 11-bit identifier
- Diagnostics
- UDS over CAN: firmware update, configuration and diagnosis
- Over-the-air updates
- Supported through a connected instrument cluster, applied over CAN
- Inputs and outputs
- Digital inputs: 3 fixed, 8 configurable. Analog inputs: 2 fixed, 1 configurable. Outputs: 2 fixed, 1 configurable
- Connector
- 23-position; mating connector TE Connectivity 770680-1 or equivalent
- Other functions
- Limp-home mode, charger interlock, motor enable/disable
- Protections
- Short circuit, overvoltage and undervoltage, overcurrent, controller and motor over-temperature, motor overrun
- Cooling
- Natural or forced
- Operating temperature
- -10 to +60 °C
- Ingress protection
- IP67
- EMI/EMC
- AIS 004, Part 3
- Weight
- ~1.2 kg
- Size (W x L x H)
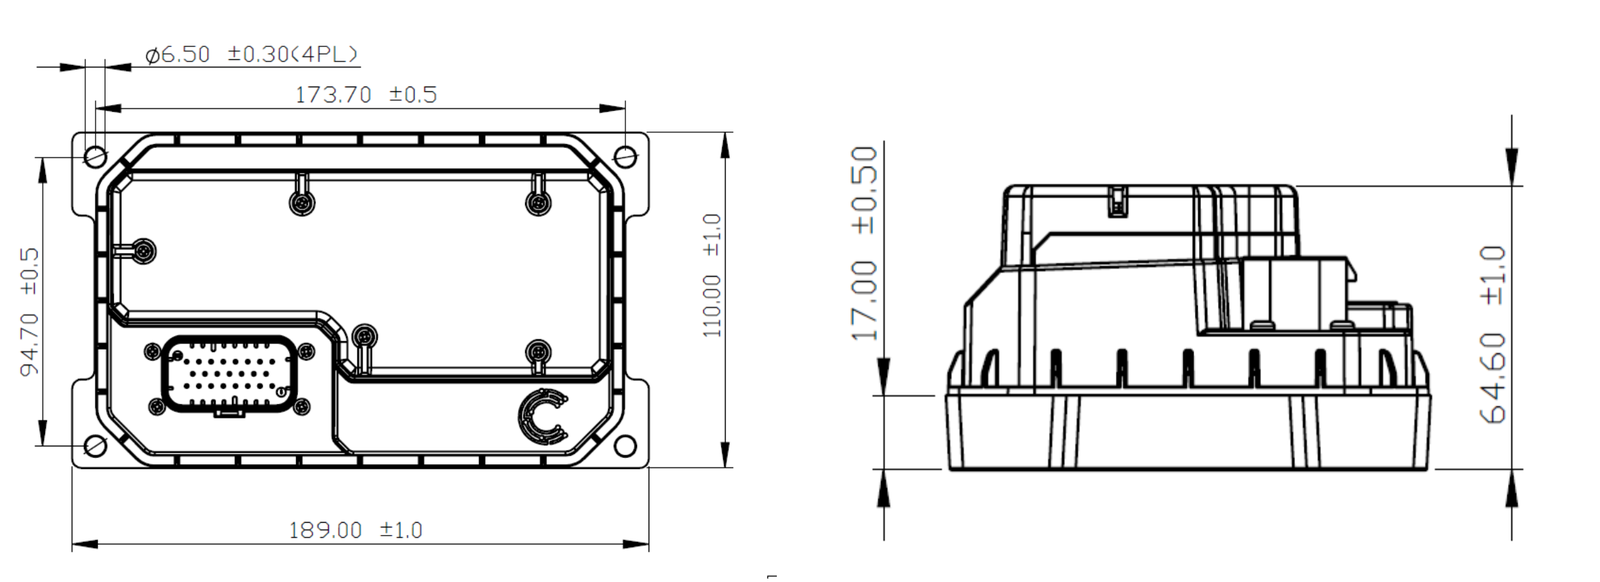
- 190 x 110 x 65 mm
Need the datasheet as a PDF? Request it from Downloads.
Views
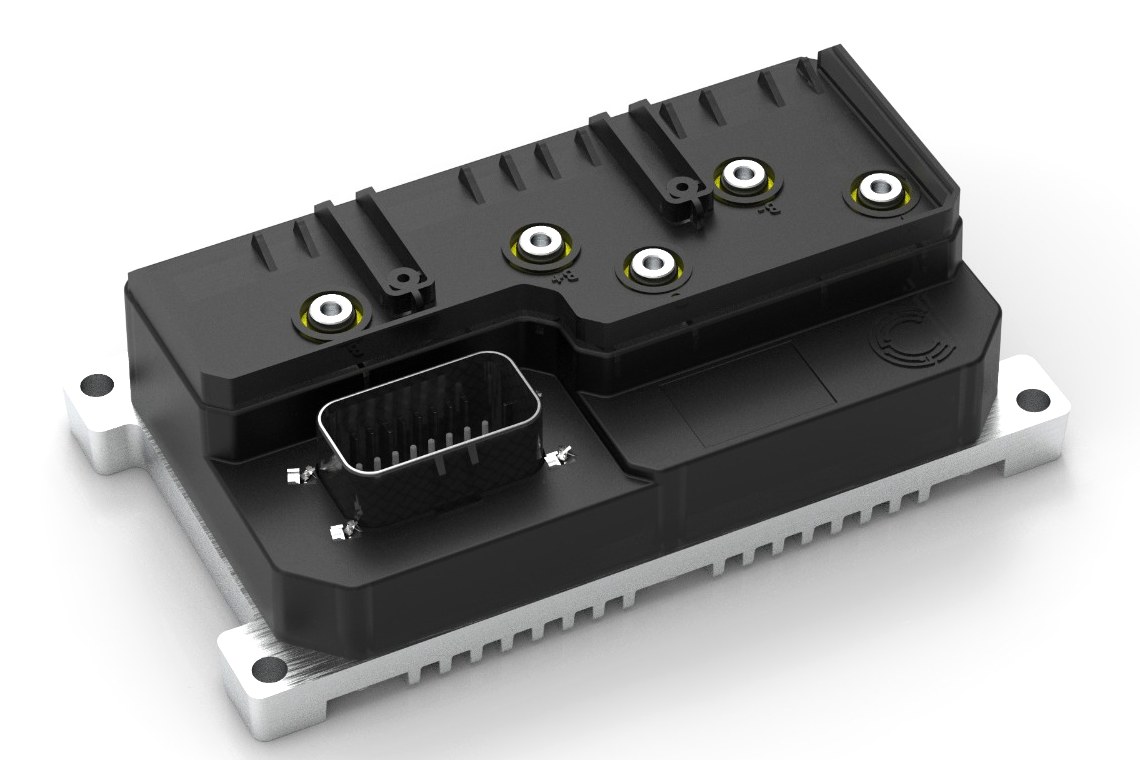
Dimensions
Connector pinout
23-position connector. Mating connector: TE Connectivity 770680-1 or equivalent.
| Pin | Function |
|---|---|
| 1 | ADC input, throttle |
| 2 | Throttle +ve |
| 3 | Ground |
| 4 | Ground |
| 5 | Ignition |
| 6 | Position sensor +ve (Hall / sin-cos / ABZ) |
| 7 | Active low input / Encoder B |
| 8 | Active high/low input |
| 9 | ADC input |
| 10 | No connection |
| 11 | ADC input, motor temperature sensor |
| 12 | Hall V / Encoder Z / Sin-cos B |
| Pin | Function |
|---|---|
| 13 | Active high/low input |
| 14 | Active high/low input |
| 15 | Active high/low input |
| 16 | Active high input |
| 17 | Single-line communication (DS) |
| 18 | Active high input (high brake) |
| 19 | Active low input / Reverse |
| 20 | Hall U / Encoder A / Sin-cos A |
| 21 | Hall W / Encoder PWM |
| 22 | CAN L |
| 23 | CAN H |
For wiring, use the released datasheet for your part number.
Part of one platform
One software stack
All four series share the same software core, so a vehicle platform can move up in power without starting again.
Tuned to your vehicle
Torque maps and regeneration strategy are set in firmware for each programme.
Built for India
Optimised for Indian drive cycles and rated for heat, dust and vibration.
Local engineering
Hardware, firmware and algorithms are our own, supported by engineers in India.
Other series
Have a vehicle programme in mind?
Send your vehicle, voltage, power and annual volume. An application engineer will reply with the right part number.